Bitácora
Programming on the pendant
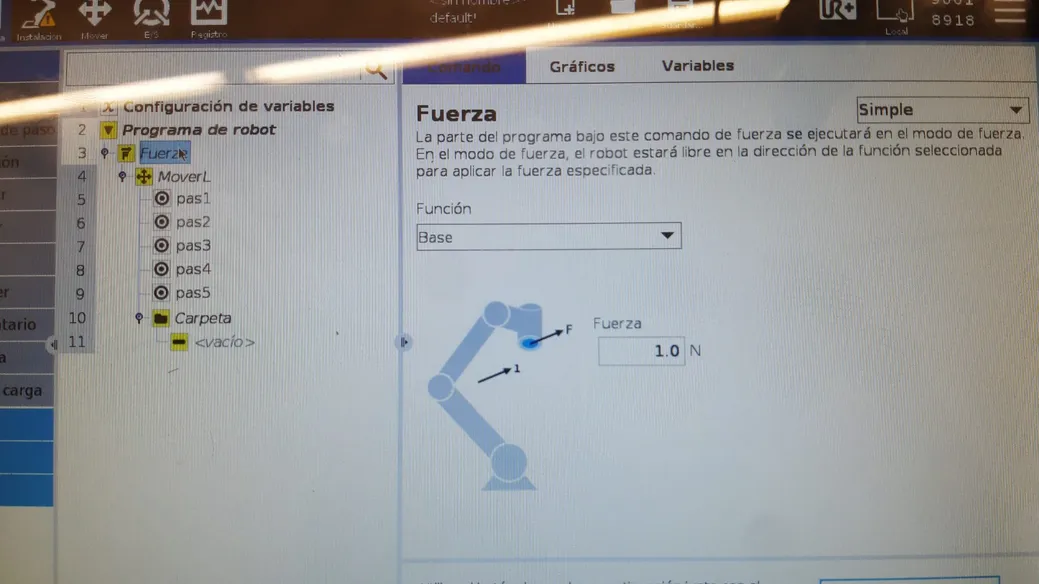
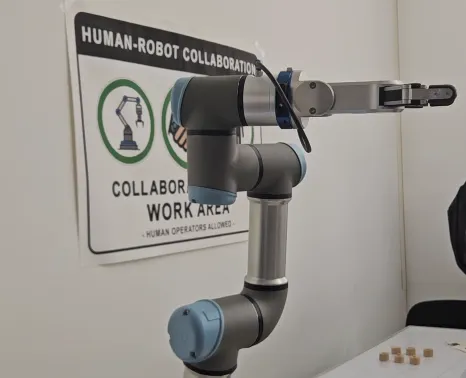
In the Robotics subject at UPC FIB we had an assignment to program a UR3e cobot through PolyScope, the interface on its touchscreen teach pendant. The goal was to build pick-and-place and palletizing programs and then try them out on the real robot in the laboratory.
From the terminal
We then went a step further and programmed the robot from our own computers, writing URScript commands in the terminal and sending them to the controller over TCP ports instead of using the pendant.
We ended up really enjoying the process. It amazed me how simple URScript commands, written in a simple and intuitive way in 3D space, translated into extremely precise movements, and even precise forces.
A surgical touch
One of the tasks, shown in the operation video, was to move the tip of the robot as if in a surgical procedure, running it over the skin of a neck mock-up while controlling the force it applied.
Video y fotos